λ₀: Scaling Open-World Egocentric Human Data for Humanoid Loco-Manipulation
Technical Report, 2026
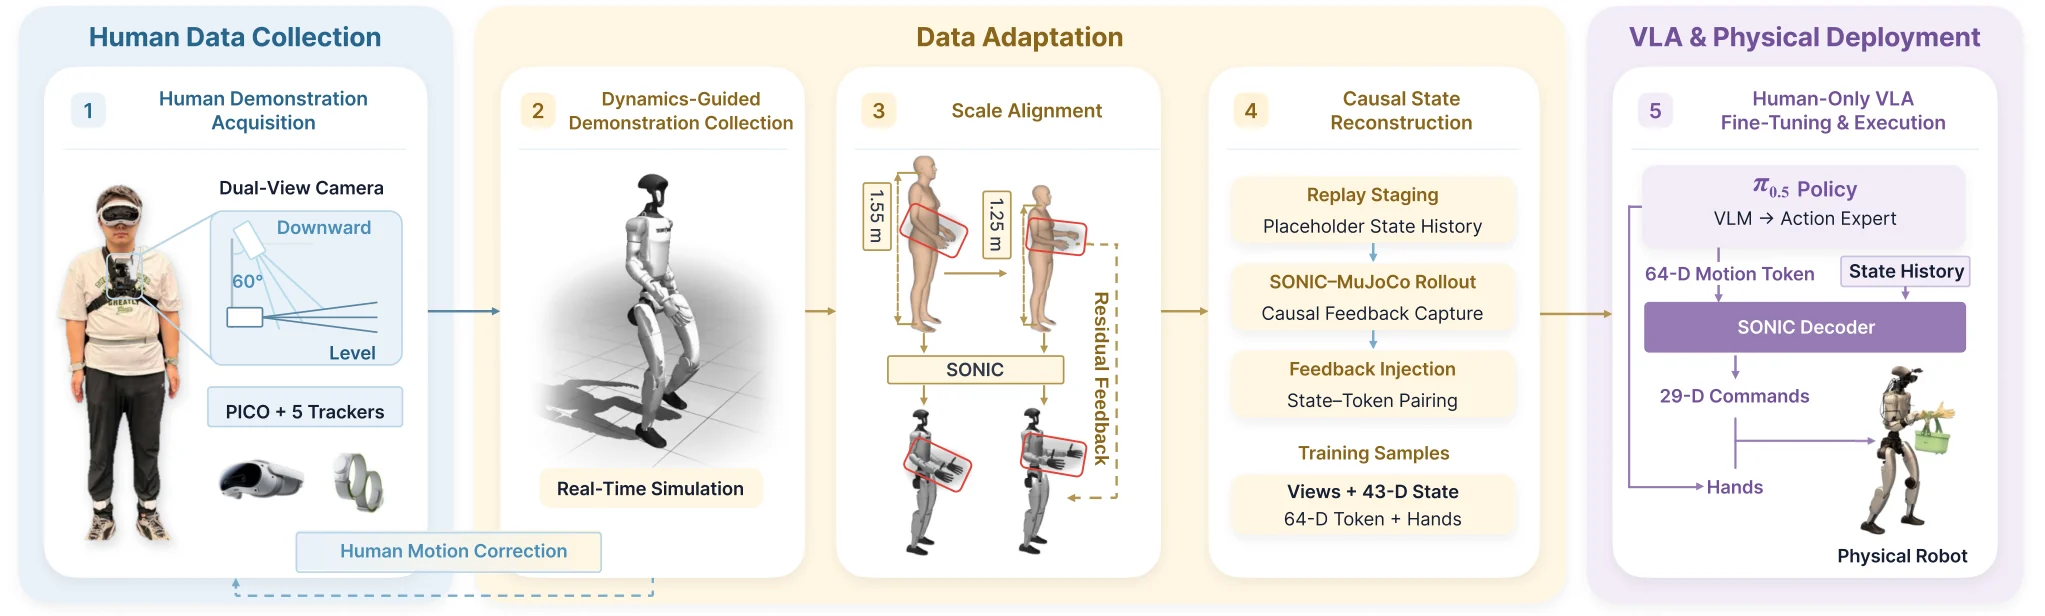
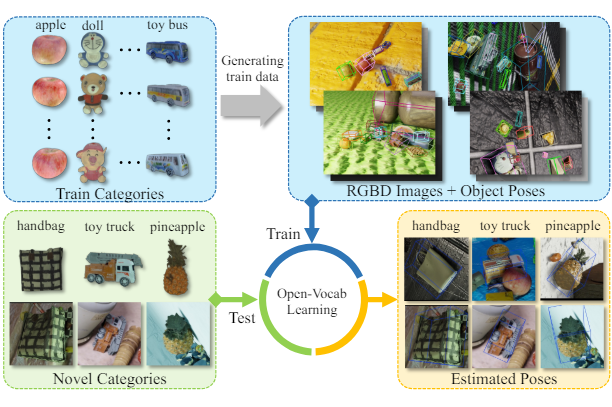
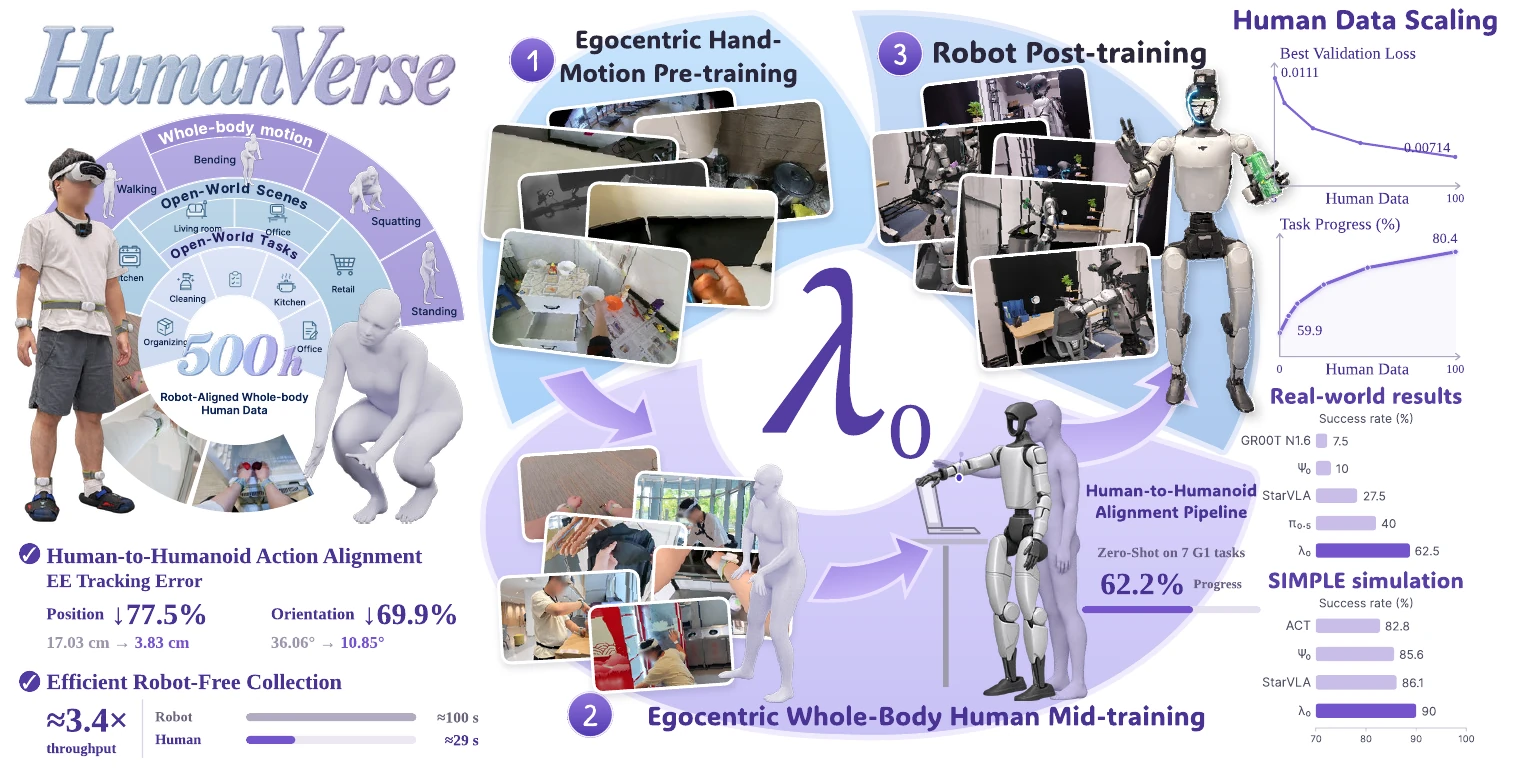
λ₀ learns whole-body humanoid loco-manipulation through egocentric pretraining, mid-training on the 500-hour HumanVerse dataset with human-to-humanoid alignment, and robot post-training. Scaling whole-body human data improves downstream task performance.